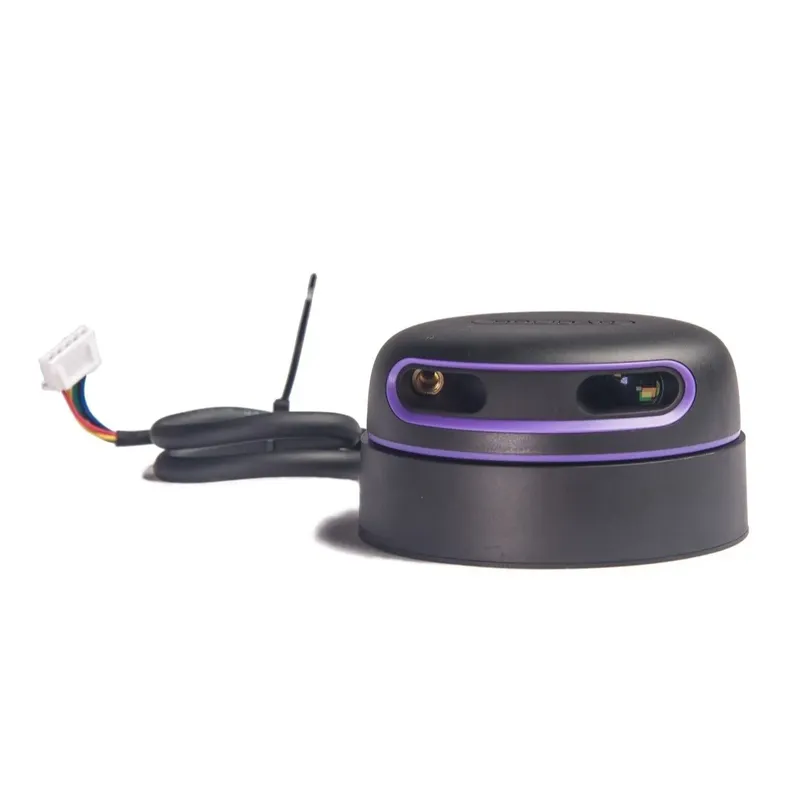
Okdo LiDAR HAT with Bracket for LD06 (Raspberry Pi Development Kit)
Prices updated: 12 Oct 2026
Compare prices
| Store | product | Price | View in store |
|---|---|---|---|
 MicroohmCheapest | Okdo Lidar HAT Module with Bracket Development Kit for LiDAR_LD06 Raspberry Pi SBC | 4,500 EGP5,000 | View in store |
 Makers Electronics | Okdo Lidar HAT Module with Bracket Development Kit for LiDAR_LD06 Raspberry Pi SBC | 4,750 EGP | View in store |
Price history
Lowest daily price, last 90 days
Not enough price history yet.
Lowest price recorded: 4,500 EGP
About this product
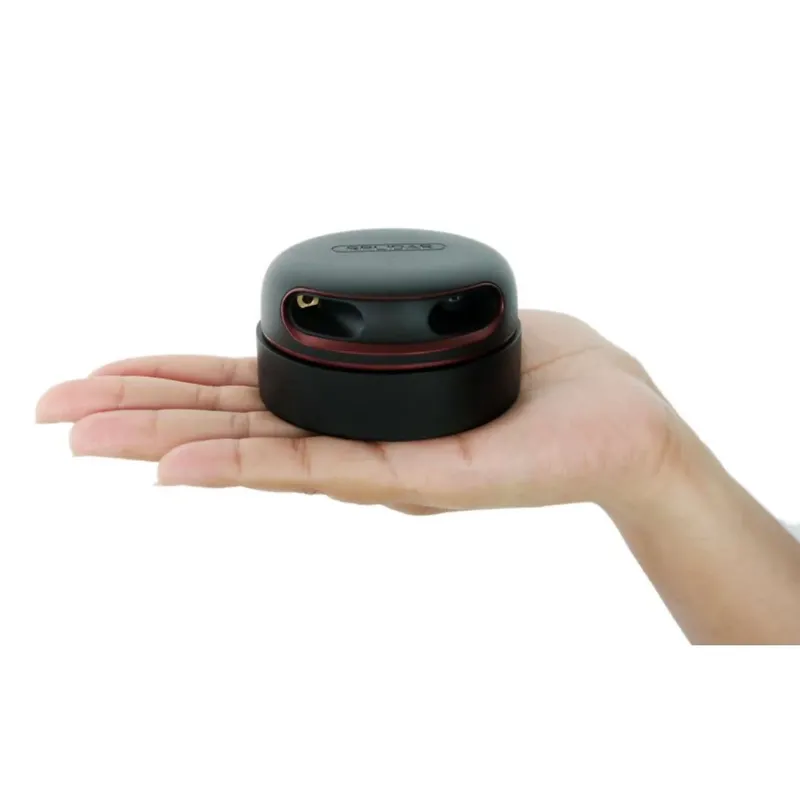
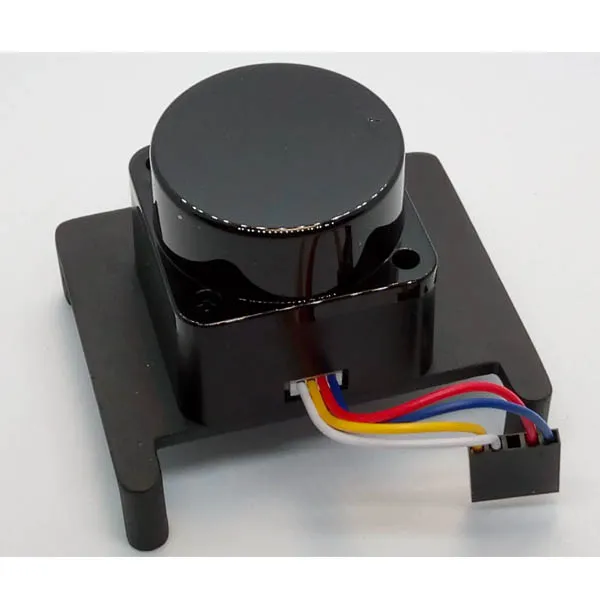
A Raspberry Pi HAT that carries the LD06 time-of-flight LiDAR sensor with a mounting bracket. It performs 360-degree distance scanning, obstacle detection and map building indoors and outdoors, and suits mobile robot and navigation projects. Compatible with Raspberry Pi 3 A+, 3 B+, 3 B and 4 B.
Specifications
- Detection range
- 0.02 m to 12 m
- Scan angle
- 360°
- Ranging technology
- TOF (time of flight)
- Interface
- UART
- Compatible boards
- Raspberry Pi 3 A+, 3 B+, 3 B, 4 B
- Expected lifetime
- Up to 10000 hours
Frequently asked questions
What is the price of Okdo LiDAR HAT with Bracket for LD06 (Raspberry Pi Development Kit) in Egypt?
Okdo LiDAR HAT with Bracket for LD06 (Raspberry Pi Development Kit) currently costs between 4,500 and 4,750 EGP across 2 offers in Egypt.
Where can I buy Okdo LiDAR HAT with Bracket for LD06 (Raspberry Pi Development Kit) in Egypt?
Okdo LiDAR HAT with Bracket for LD06 (Raspberry Pi Development Kit) is available from Microohm and Makers Electronics. Compare the offers above to find the best price.
Which Raspberry Pi models are supported?
The listing states compatibility with Raspberry Pi 3 A+, 3 B+, 3 B and 4 B. Check the board's pinout and OS support before using it with other models.
How is the LD06 read by the Raspberry Pi?
The LD06 sends its data over a serial UART link. Enable the serial port in raspi-config, disable the serial login shell, and read the data stream in your code or a ROS driver.